ホーム > 境野 翔/ Sakaino, Sho
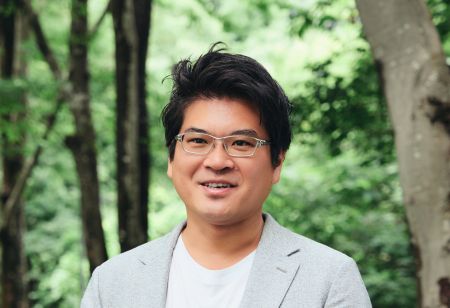
境野 翔
Sakaino, Sho
システム情報系 , 准教授 Institute of Systems and Information Engineering , Associate Professor
-
高等研究院 未知領域への挑戦者たち
2026-04-15
境野 翔
-
高等研究院 自発研究ユニットフェロー
2026-04-15
境野 翔
-
2種類の制御×AIで、家事も農作業もできるロボットに
2021-08-10
境野 翔
オープンアクセス版の論文は「つくばリポジトリ」で読むことができます。
-
1.
Design and Experimental Validation of Sensorless 4-Channel Bilateral Teleoperation for Low-Cost Manipulators
Yamane, Koki; Li, Yunhan; Konosu, Masashi; Inami, Koki (+2 著者) SAKAINO, Sho
IEEE Access 14: 109407 (2026)
-
2.
Virtual Surface Presentation Using a Rotating Cylindrical End-Effector
Yamamoto, Koki; Yoshida, Takako; SAKAINO, Sho; Tsuji, Toshiaki
IEEE Robotics and Automation Letters 11: 9899 (2026)
-
3.
ロボットの動作データのオフライン編集ソフトウェア
江﨑, 愛那; 桝屋, 望; 境野, 翔
ロボティクス・メカトロニクス講演会2026 (2026)
-
4.
QDDモータを用いたオープンソース・双腕ロボットOpenArmでのパラメータ同定の試行とバイラテラル制御に基づく繰り返し動作
桝屋, 望; 境野, 翔
ロボティクス・メカトロニクス講演会2026 (2026)
-
5.
外乱オブザーバを用いた制御系のデータ駆動型パラメータ調整
井上, 諒; 稲見, 洸紀; 大明, 準治; 境野, 翔
ロボティクス・メカトロニクス講演会2026 (2026)
-
6.
動作履歴のマスキングによる視覚情報活用を促進する模倣学習手法
稲見, 洸紀; 境野, 翔
ロボティクス・メカトロニクス講演会2026 (2026)
-
7.
Timespan-Modulated Liquid Time-Constant Networks に基づくコンタクトリッチタスクの模倣学習
境野, 翔; 大石, 涼雅; 辻, 俊明
ロボティクス・メカトロニクス講演会2026 (2026)
-
8.
Unsupervised motion primitive identification under translational physical constraints in contact-rich tasks
Oishi, Ryoga; Sakaino, Sho; Tsuji, Toshiaki
ADVANCED ROBOTICS 40: 383 (2026) Semantic Scholar
-
9.
Potential Fields for Position-Constrained Autonomous Motion in Robotic Imitation Learning
Mizutani, Kei; Konosu, Masashi; Inami, Koki; Li, YunhanSakaino, Sho
IEEJ JOURNAL OF INDUSTRY APPLICATIONS 15: 809 (2026)
-
10.
Hierarchical Proportion Models for Motion Generation via Integration of Motion Primitives
Shu, Yu-Han; Toshiaki Tsuji; SAKAINO, Sho
Proceedings of the 2026 IEEE International Conference on Advanced Motion Control (2026)
-
11.
Frequency-Designed Mamba SSM for Robot Motion Generation
Inoue, Kotaro; SAKAINO, Sho; Tsuji, Toshiaki
Proceedings of the 12nd IEEJ International Workshop on Sensing, Actuation, Motion Control, and Optimization 148 (2026)
-
12.
Why Motors with Gear Have Poor Responsiveness to Viscous Force?
Tripathi; Gyanendra Nath; Oaki, Junji; Yamane, Koki (+2 著者) SAKAINO, Sho
Proceedings of the 12nd IEEJ International Workshop on Sensing, Actuation, Motion Control, and Optimization 160 (2026)
-
13.
Force Generative Imitation Learning: Bridging Position Trajectory and Force Commands Through Control Technique
Sato, Hiroshi; Tsuji, Toshiaki; Sakaino, Sho
IEEE ACCESS 14: 26169 (2026) Semantic Scholar
-
14.
制御周期の短縮によるバイラテラル制御の高精度化と学習応用の可能性
稲見, 洸紀; 大明, 準治; 境野, 翔; 辻, 俊明
Journal of the Robotics Society of Japan 44: 332 (2026)
-
15.
Imitation Learning Based on Disentangled Representation Learning of Behavioral Characteristics
Oishi, Ryoha; Tsuji, Toshiaki; SAKAINO, Sho
Proceedings of the 9th Conference on Robot Learning 4625 (2025)
-
16.
学習済みモデルを用いた解釈可能な階層型模倣学習における柔軟適応・高速力生成下位層モデルの提案
LI, YUNHAN; 鴻巣匡志; 山根広暉; 境野, 翔辻俊明
日本ロボット学会学術講演会論文集 (2025)
-
17.
π0とALOHA2に基づく物体操作の一検討
桝屋望; LI, YUNHAN; 鴻巣匡志; 稲見洸紀境野, 翔
日本ロボット学会学術講演会論文集 (2025)
-
18.
CRANE-X7各軸のモデリングと7軸フルダイナミクスのパラメータ同定
大明準治; 山根広暉; 稲見洸紀; 境野, 翔
日本ロボット学会学術講演会論文集 (2025)
-
19.
スケーリング付きバイラテラル制御に基づく模倣学習
本間真之介; 境野, 翔; 辻俊明
電気学会産業応用部門大会講演論文集 (2025)
-
20.
角度と角速度の関係性を考慮したバイラテラル制御に基づく模倣学習
佐藤, 寛; 桝屋, 望; 山根, 広暉; 稲見, 洸紀 (+2 著者) 辻, 俊明
日本ロボット学会誌 43: 603 (2025)
-
1.
Advanced Motion Control for Tasks in Open Environment
Sakaino,Sho
2011年3月
-
261.
Bidirectional Contactless Power Transfer System Expandable from Unidirectional System
Nakadachi, Soichiro; Mochizuki, Shigeru; Sakaino, Sho; Kaneko, Yasuyoshi; Abe, Shigeru; Yasuda, Tomio
the IEEE Energy Conversion Congress and Exposition 2013
-
262.
Experimental Evaluation of Bilateral Control of Velocity Control System Using Electric and Hydraulic Actuators
Takahashi, Daiki; Furuya, Takayuki; Sakaino, Sho; Tsuji, Toshiaki
the 39th Annual Conference of the IEEE Industrial Electronics Society
-
263.
Simplified Whole-Body Tactile Sensing System Using Soft Material at Contact Areas
Kurita, Naoyuki; Hasunuma, Hiroaki; Sakaino, Sho; Tsuji, Toshiaki
the 39th Annual Conference of the IEEE Industrial Electronics Society
-
264.
Classification of a Hybrid Control System for Robotic Tool Use
Matsuzaki, Ryohei; Kamibayashi, Makoto; Sakaino, Sho; Tsuji, Toshiaki
2013 IEEE International Conference on Mechatronics
-
265.
An Extended Jacobian Matrix and Multirate Control for Bilateral Control between Different Time Resolution Systems
Sakaino, Sho; Tsuji, Toshiaki
the 38th Annual Conference of the IEEE Industrial Electronics Society
-
266.
Whole-body Force Sensation by Force Sensor with End-effector of Arbitrary Shape
Kurita, Naoyuki; Sakaino, Sho; Tsuji, Toshiaki
the 2012 IEEE/RSJ International Conference on Intelligent Robots and Systems
-
267.
High Bandwidth Attitude Control Based on Musculoskeletal System with Biarticular Muscles
Tsuji, Toshiaki; Yokoo, Tomonori; Sakaino, Sho
the 2012 IEEE/RSJ International Conference on Intelligent Robots and Systems
-
268.
Development of a Physical Therapy Robot for Rehabilitation Databases
Tsuji, Toshiaki; Yokoo, Tomonori; Sakaino, Sho
Proceedings of the 12th IEEE International Workshop on Advanced Motion Control
-
269.
Velocity Constrained Mobile-hapto by Coordinate Transformation
Sakaino, Sho; Sato, Tomoya; Ohnishi, Kouhei
the 1st International Symposium on Access Spaces
-
270.
Motion Reproduction System of Manipulating and Grasping Motion for Grasping Objects of Unknown Size
Sato, Tomoya; Sakaino, Sho; Ohnishi, Kouhei
the 1st International Symposium on Access Spaces
-
271.
Adaptation Method Using Environmental Modes for Biped Robot with Toe and Heel Joints on Unknown Uneven Terrain
Sato, Tomoya; Sakaino, Sho; Ohnishi, Kouhei
the 2011 IEEE International Conference on Mechatronics
-
272.
Adaptation Method Using Environmental Modes for Biped Robot with Toe and Heel Joints on Unknown Uneven Terrain
Sato, Tomoya; Sakaino, Sho; Ohnishi, Kouhei
the 2011 IEEE International Conference on Mechatronics
-
273.
Mobile-hapto with Yaw Rate Control for Traveling on Rough Terrain
Sakaino, Sho; Sato, Tomoya; Ohnishi, Kouhei
Proceedings of the 36th Annual Conference of the IEEE Industrial Electronics Society
-
274.
Switching Impedance Control in Vertical Direction for Biped Robot with Toe and Heel Joints on Uneven Terrain
Sakaino, Sho; Sato, Tomoya; Ohnishi, Kouhei
the 36th Annual Conference of the IEEE Industrial Electronics Society
-
275.
Constrained Bilateral Control by Oblique Coordinate Control Taking Priority of Tasks into Account
Sakaino, Sho; Sato, Tomoya; Ohnishi, Kouhei
Proceedings of the International Powerelectronics Conference 2010
-
276.
A Novel Motion Equation for General Task Description
Sakaino, Sho; Sato, Tomoya; Ohnishi, Kouhei
the 11th IEEE International Workshop on Advanced Motion Control
-
277.
Trajectory Planning and Control for Biped Robot with Toe and Heel Joints
Sakaino, Sho; Sato, Tomoya; Ohnishi, Kouhei
the 11th IEEE International Workshop on Advanced Motion Control
-
278.
Methods for Reduction of Operational Force in Force Sensor-less Bilateral Control with Thrust Wire
Sato, Tomoya; Sakaino, Sho; Ohnishi, Kouhei
the 3rd Conference on Human System Interactions
-
279.
Keynote paper –Real World Haptics Applied to Forceps in Robot Surgery,
Sakaino, Sho; Abeykoon; A. M; Harsha S; Ohnishi, Kouhei
Proceedings of the IEEE 5th International Conference on Information and Automation for Sustainability 招待有り
-
280.
Task Hierarchy for Position Limitation and Bilateral Control by Oblique Coordinate Control
Sakaino, Sho; Sato, Tomoya; Ohnishi, Kouhei
the 35th Annual Conference of the IEEE Industrial Electronics Society
-
1. 2015-537631: 位置・力制御装置、位置・力制御方法及びプログラム
境野,翔 -
2. 2015-142500: 機能的電気刺激を用いた双方向遠隔制御システム
境野,翔 -
3. 2015-142500: 機能的電気刺激を用いた双方向遠隔制御システム
境野,翔 -
4. 2015-142500: 機能的電気刺激を用いた双方向遠隔制御システム
境野,翔 -
5. 2015-142500: 機能的電気刺激を用いた双方向遠隔制御システム
境野,翔 -
6. 特願2020-514025: 行動推定装置、行動推定方法、および行動推定プログラム
境野, 翔 -
7. : Behavior Estimation Apparatus, Behavior Estimation Method, and Behavior Estimation Program
Sakaino, Sho -
8. : Behavior Estimation Apparatus, Behavior Estimation Method, and Behavior Estimation Program
Sakaino, Sho -
9. : Behavior Estimation Apparatus, Behavior Estimation Method, and Behavior Estimation Program
Sakaino, Sho -
10. : Behavior Estimation Apparatus, Behavior Estimation Method, and Behavior Estimation Program
Sakaino, Sho -
11. 2022-536319: 情報処理装置、方法、及びプログラム
境野,翔 -
12. 2022-536319: Information Processing Device, Method, and Program
SAKAINO, Sho
2,921 total views
この研究者の他の情報源
 ORCID
キーワードが似ている研究者
- ARANHA CLAUS DE CASTRO machine learning, Machine Learning
- 德田 慶太 ALUMNI machine learning, machine learning
- 小平 大輔 machine learning, Machine Learning
- YEM VIBOL Haptics, ロボティクス
- 北村 豊 ロボット
この研究者の情報を共有